AutoSpeed and Object Finder: An Open Source, Camera-Only Neural Network Framework
AutoSpeed with Object Finder is an open source, camera-only neural network framework designed to detect critical obstacles in real-world driving scenes.
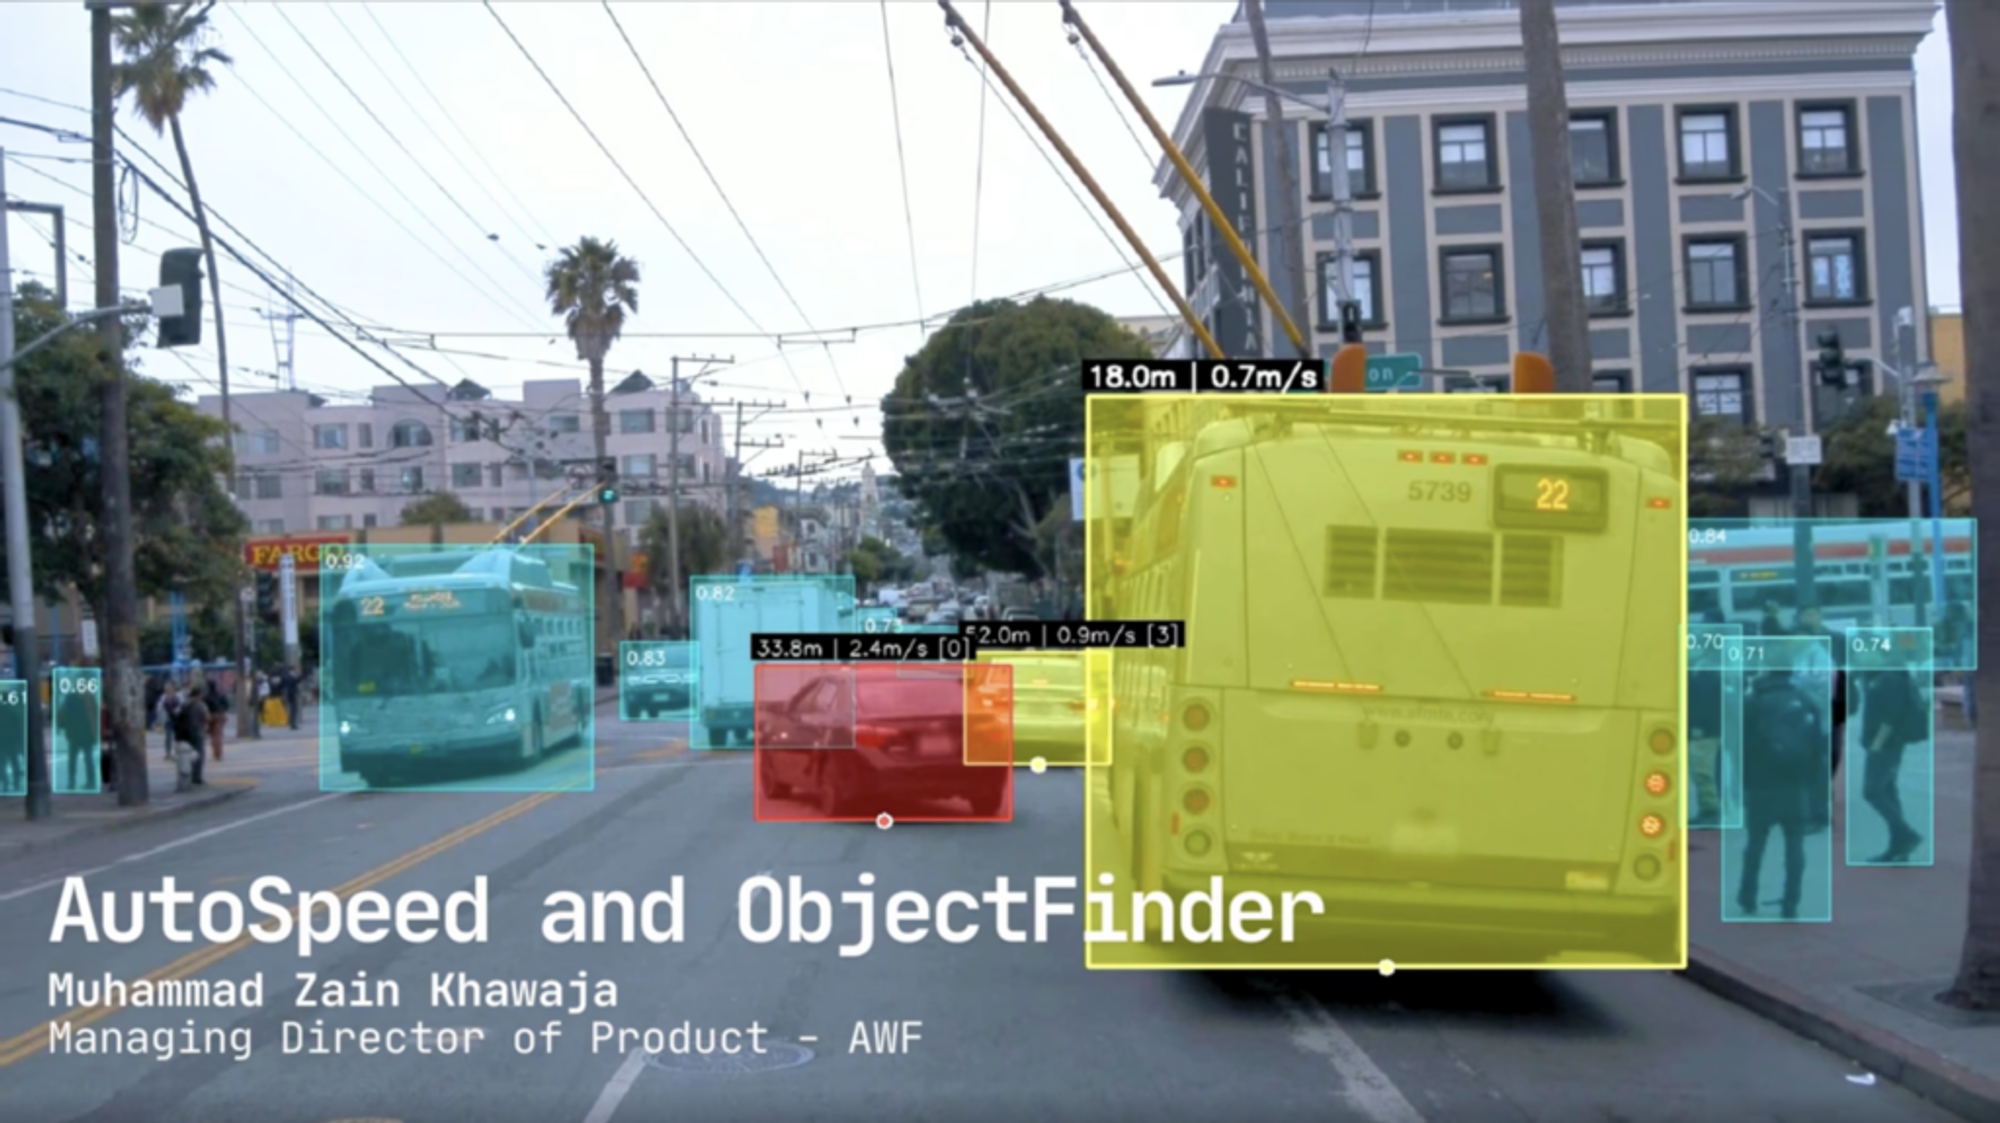
Another milestone from the Privately Owned Vehicle (PoV) Working Group at the Autoware Foundation 🚗
Today, we’re showcasing AutoSpeed with Object Finder — an open source, camera-only neural network framework designed to detect critical obstacles in real-world driving scenes.
From a single front-facing camera, the system: 🔵 Detects all relevant foreground objects 🔴 Identifies the closest in-path object 🟡 Tracks cut-in and cut-out vehicles — without explicit lane detection
This enables key ADAS & autonomy features: 🔸 Forward Collision Warning 🔸 Automatic Emergency Braking 🔸 Autonomous Cruise Control
Works on all road types: 🔹 Highways, urban streets, unstructured roads 🔹 Even where lane lines are missing or unreliable
Robust in the real world: 🌧️ Rain, water droplets on the lens 🌙 Nighttime & low-light conditions 🛣️ Straight roads and high-curvature scenarios
Smart perception, simplified sensing: 📏 Distance & relative speed estimated directly 📷 No LiDAR. No Radar. Just vision.
Beyond vehicles 🚲🚶 The system reliably detects pedestrians, bicyclists, and other critical road users — supporting safer decision-making in complex urban traffic.
AutoSpeed + Object Finder together form a powerful open source vision stack for real-time autonomous driving — built by the community, for the community, and ready for OEMs and Tier-1 suppliers to experiment, extend, and deploy.
The link to the AutoSpeed network GitHub page is in the first comment. Check it out!
👏 Huge thanks to the contributors who made this possible: 🏆 Atanasko Boris Mitrev — AutoSpeed neural network development & training 🏆 Pranav Doma — Object Finder module
🔜 More PoV Working Group breakthroughs are coming soon.